Posts with «face tracking» label

Face-tracking robot with Arduino UNO Q

An inexpensive robot kit with Arduino UNO Rev3, obstacle-avoidance sensors, and line-following capability becomes a face-tracking robot. The trick is in the control board: just replace the UNO Rev3 with an Arduino UNO Q, which has the same headers and mounts an STM32U585 microcontroller alongside a Linux microprocessor. Iulia Feroli’s project shows how local artificial intelligence can be added to a low-cost robot without touching the mechanics.

The robot starts from the Elegoo kit, with its motor shield and sensors for obstacle avoidance and line following. The UNO Q slots in place of the original board, and the shield moves over without any modification. Thanks to the STM32 microcontroller and the Linux microprocessor, the new board runs machine learning models locally, with no cloud connection. A standard USB webcam is connected to the UNO Q to provide vision.

Video stream and face tracking

The webcam video stream is processed with the face tracking Brick from Arduino App Lab. The code converts the face position in the frame into movement commands for the robot. The robot rotates to center the face and moves toward it, always staying in front of the person. The result is a responsive face tracker that requires no external servers or Wi-Fi connections.

Iulia Feroli’s project is documented in a video showing the robot in action, with an explanation of the assembly and the code. Swapping the board is the core of the intervention: the UNO Q maintains electrical and mechanical compatibility with the UNO Rev3 but adds the computing power needed for AI. In addition, the face tracking Brick in Arduino App Lab simplifies managing the machine learning model, making the code accessible even to those without neural network experience.

What you need to rebuild the project

To replicate the robot you need only a few components, all easily available. The list includes the Elegoo kit, a USB webcam, and the control board. Here are the main steps:

  • Remove the Arduino UNO Rev3 from the Elegoo kit and keep the motor shield.
  • Mount the Arduino UNO Q in its place, checking that the headers align.
  • Connect the USB webcam to the UNO Q port.
  • Upload the sketch with the face tracking Brick from Arduino App Lab.
  • Power the robot and test it in front of a face.

The UNO Q is the heart of the system: it combines the simplicity of the STM32U585 microcontroller with the power of the Linux processor. This combination allows local machine learning models, such as face tracking, to run without additional hardware. The board is also available in a 4GB version with a full accessory kit, which includes everything needed to get started.

The original Elegoo kit, with its Arduino UNO Rev3 board, remains an excellent base for other projects. However, for this face tracker, the UNO Q is the right choice: it offers the necessary computing power and maintains compatibility with the shield. The overall cost stays low, and the result is a smart robot that impresses with its responsiveness.

Source: https://youtu.be/FIu14vCvGfs?si=8SSW0K6O7J6Y07tz

The post Face-tracking robot with Arduino UNO Q appeared first on Open Electronics.
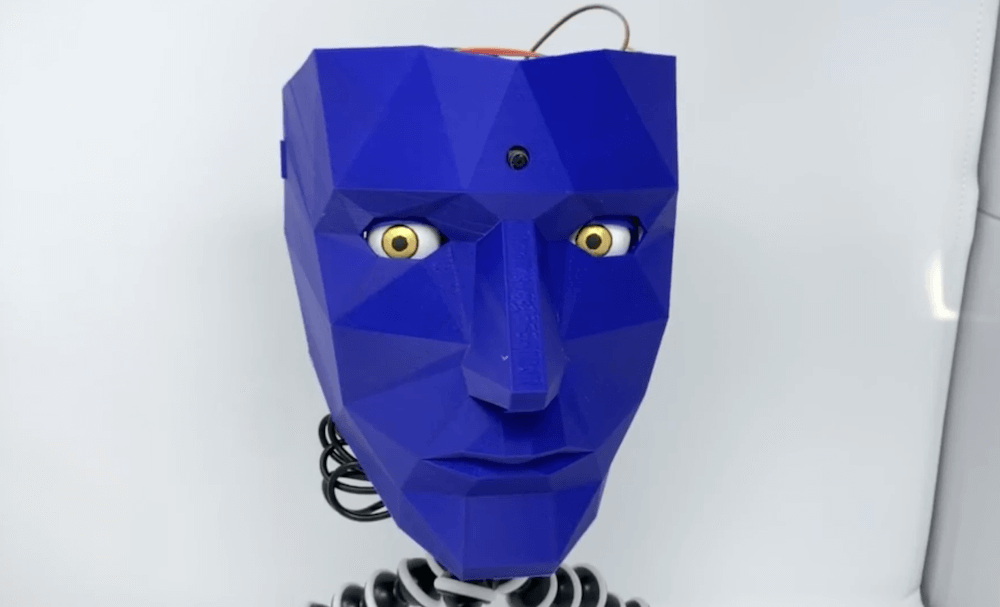
The Watchman is a 3D-printed robot head that follows your face with realistic eyeballs

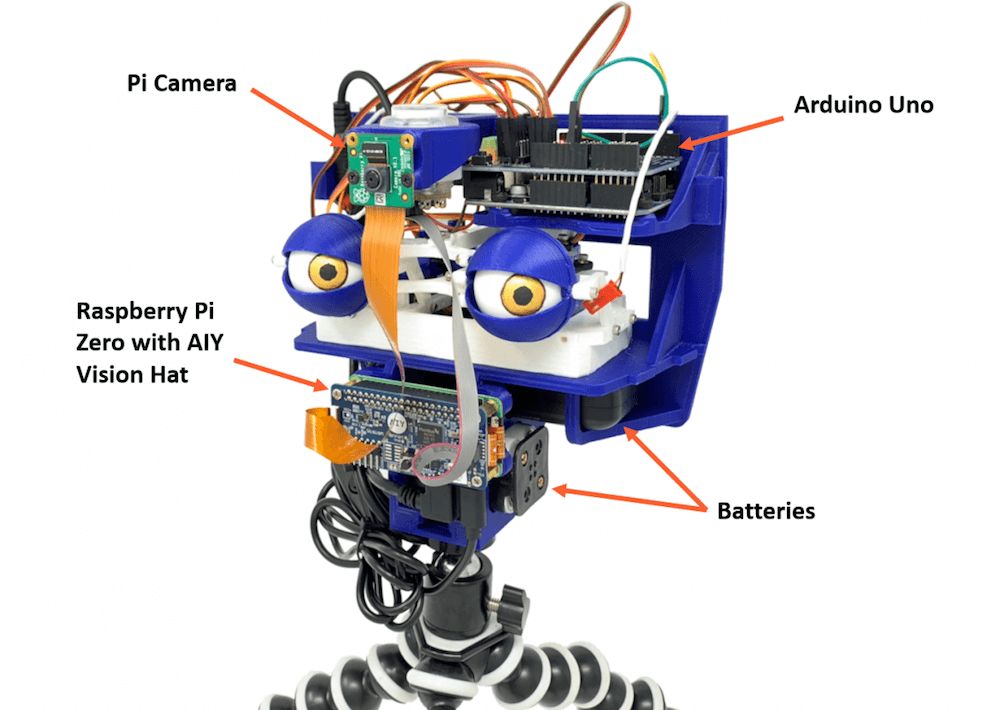
When you step out in public, you’ll often be filmed by a number of cameras and perhaps even be analyzed by tracking software of some kind. The Watchman robot head by Graham Jessup, however, makes this incredibly obvious as it detects and recognizes facial movements, then causes a pair of eyeballs to follow you around.

The 3D-printed system — which is a modified version of Tjhazi’s Doorman — uses a Raspberry Pi Camera to capture a live video feed, along with a Raspberry Pi Zero and a Google AIY HAT for analysis.

This setup passes info on to an Arduino Uno that actuates the eyeballs via a 16-channel servo shield and a number of servos. The device can follow Jessup up, down, left, and right, making for a very creepy robot indeed!

Face tracking with Arduino and Android

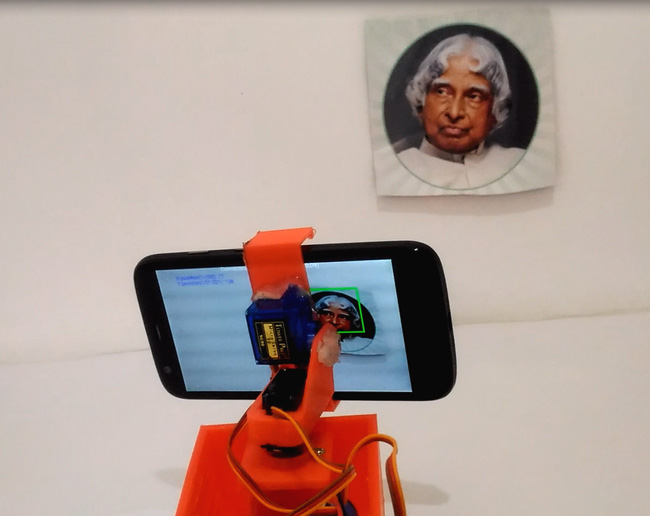
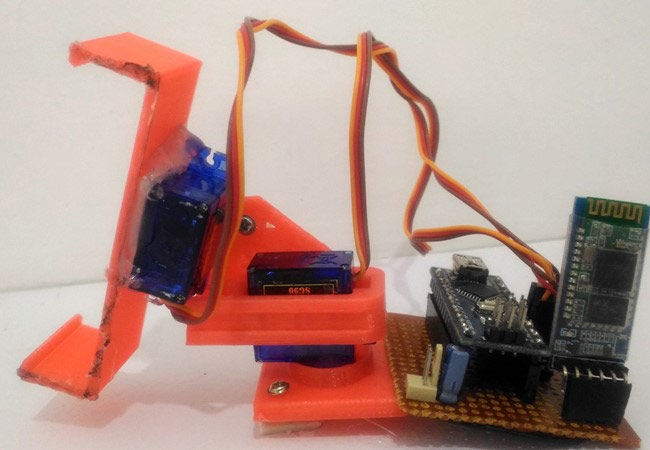
Computer vision has traditionally relied on an assortment of rather involved components. On the other hand, everything you need to do this complicated task is readily available on an Android phone. The clever setup seen in the video here uses a smartphone to capture and process images, then send out a signal over Bluetooth to tell which way the device needs to be adjusted in order to focus on a nearby face.

An HC-05 Bluetooth module receives this signal and passes it to two servo motors via an Arduino Nano, moving the phone left/right and up/down.

You can find the Arduino code for this project on CircuitDigest, and the Android Processing code can be downloaded there as a compressed folder.

Googly Eyes Follow You Around the Room

If you’re looking to build the next creepy Halloween decoration or simply thinking about trying out OpenCV for the first time, this next project will have you covered. [Glen] made a pair of giant googly eyes that follow you around the room using some servos and some very powerful software.

The project was documented in three parts. In Part 1, [Glen] models and builds the eyes themselves, including installing the servo motors that will eventually move them around. The second part involves an Arduino and power supply that will control the servos, and the third part goes over using OpenCV to track faces.

This part of the project is arguably the most interesting if you’re new to OpenCV; [Glen] uses this software package to recognize different faces. From there, the computer picks out the most prominent face and sends commands to the Arduino to move the eyes to the appropriate position. The project goes into great detail, from Arduino code to installing Ubuntu to running OpenCV for the first time!

We’ve featured some of [Glen]’s projects before, like his FPGA-driven LED wall, and it’s good to see he’s still making great things!


Filed under: video hacks

L33T - Personal service robot

Primary image

What does it do?

Personal assistance (Butler)

Time to make a formal reveal as to the project I am working on, L33T. The idea behind L3 is to be a personal service robot, to help out wherever he can and interact with people in the household, efectively being a robot butler. 

When thinking of what L3 should be and what it should look like I drew a lot of inspiration from R2, even the naming scheme is similar. R2 was able to manevour well in tight situations, he could 'talk' to and understand people, and was capable of performing bulter like tasks. 

Cost to build

$100,00

Embedded video

Finished project

Number

Time to build

Type

wheels

URL to more information

Weight

read more

Face tracking with Arduino, Processing and OpenCV

How this actually works is described about below but also in the video. I suggest you watch the video as my writing is terrible.

Video : http://www.youtube.com/watch?v=1cEp7duDbNU&feature=plcp

The Processing code : https://www.dropbox.com/sh/v9hkdxuoazoyb0d/fCGQzEfBAK The OpenCV and Arduino libraries are needed. OpenCV also needs to be installed onto the computer.

The Arduino code : https://www.dropbox.com/sh/ujjlahx83ilv1j2/QB0bu8E-EJ

read more

MAKEmatics – Mathematics for Makers

Makers need to familiarize themselves with the core concepts and the theory involved in creating applications such as Motion Sensing and Face Tracking. As the technology is churning out new hardware day and night, DIYers need to work hard to keep up and always be in touch with the latest technology around them.

-->-->

For example, anyone working with Accelerometers/ Gyroscopes or Inertial Measurement Units needs to understand the theory of Vectors, Force, Gravity and be able to work out complex mathematical problems. They may easily get an Arduino Board and an Accelerometer Breakout or an IMU Board and use a library instead of writing their own code but to truly understand the theory behind it; how the device actually works, is not for the faint of heart.


One such problem is the Face Tracking Application. Unless you know the real theory behind how the Algorithm actually works, you can only wonder about that robot which follows its master. Greg Borenstein had an idea of creating a website dedicated to this issue. Makematics – Math for Makers.


In an introductory post, Greg writes:

” I hope to show that a normal programmer with no special academic training can grapple with these areas of research and find a way in to understanding them. And as I go I aim to create material that will help others do the same. If I can do it, there’s no reason you can’t.”

More and more people should step forward and create or compile a good amount of research data to help fellow makers and DIYers in solving complex mathematical problems.