


Posts with «robot» label

Want to learn Arduino? Use this educational Microbot!
Primary image

What does it do?
Educates people on arduino
Introducing the latest creation from B.O.T, the SWARMµBOT. An Arduino-Compatible educational micro-bot with all sensors required for applications such as Line-Following, Maze Solving, And Swarming! With a Atmega328 running an Arduino-compatible bootloader, and an integrated USB-UART bridge, programming this bot is as easy as connecting a USB cable, and hitting upload.
Cost to build
$99,95
Finished project
Complete
Number
Time to build
0 hours
Type
URL to more information
Weight
65 grams
Introducing BoardX: The Open Source Miniature Robotics Motherboard
Hi Everybody!
Long time robot enthusiast here, but just joined up after searching for some robotics tutorials. I'm searching for ideas to create a beginners robotics kit for my open source project, BoardX.
I'm going to post some information here, and if anybody is interested in purchasing one, send me an email and I'll give you instructions on how to get a discount!

Here's my site: http://www.upgradeindustries.com
How many robots?
How many robots run on Arduino? I really don’t know. The guys from Complubot keep on sending pictures from the robots they are finding at the Robo Cup in Mexico DF. Want to see some pictures? Look at the following:

(c) 2012 Complubot, Japanese Team on Soccer B
The Japanese Team on Soccer B have been working with Arduino for 3 years now. The robots on the picture are only using our IDE, as they made their own PCBs to host 8 InfraRed sensors, a compass, and the motor drivers. Take a closer look at it on the next picture.
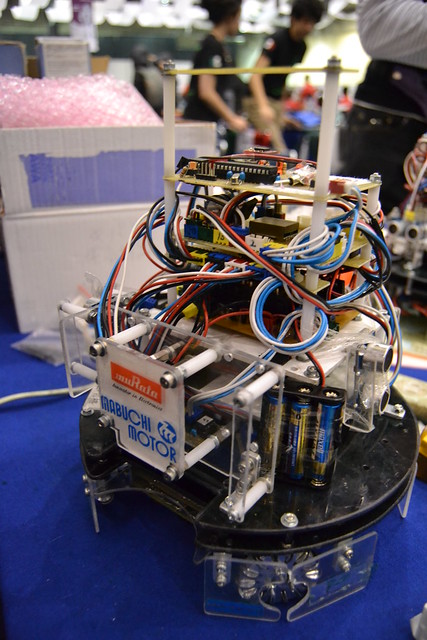
(c) 2012 Complubot, Japanese Soccer B team at RCJ Mexico DF
On the other hand, the German team, running on an Arduino Mega, are controlling 60 InfraRed sensors to detect the ball on the field. They got the 1st price on Soccer A Open and have been using Arduino for just one year.

(c) 2012 Complubot, German Soccer A Open team (winner)
I bet you want to see that robot closer, 60 IR sensors are quite many. It also controls 4 UltraSound sensors and 1 Compass. Quite an achievement. Look at this:

(c) 2012 Complubot, German Soccer A Open robot
Well, the picture isn’t very sharp, but you can clearly see the amount of sensors on that machine. I have to make some more research to understand what is the black plastic thingy on the top board of the robot. It feels like some sort of exhaust pipe. The black dots on the red PCB are the IR sensors.
If there is a team that beats all about the amount of time they have been working with Arduino, is the Mexican coming from UNAM. On the Soccer B category, these guys have been running their robot on Arduino for only 2 months!! They are however controlling 8 IR sensors and one Compass over I2C.

(c) 2012 Complubot, Mexican (UNAM) Soccer B team
Also from Mexico, this time participating on the Rescue competition, we find a team with a really broad age range. The team from Monterrey ranges between 10 and 19 and made a robot controlled by Arduino Uno.
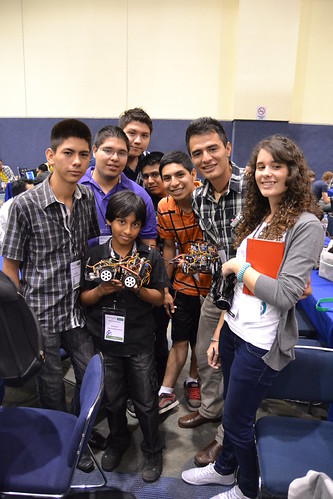
(c) 2012 Complubot, Moterrey Rescue Team
The Swiss team has been using Arduino during 2 years and are the only one in my list that have started using a camera. They run their bots on Arduino Mega and control 12 IR and 4 US sensors.
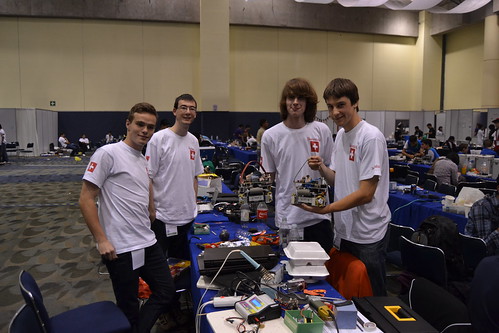
(c) 2012 Complubot, Swiss Soccer B team
If there is a country that is well know for soccer that is Brazil. Their Rescue A team at the RCJ looks like this:
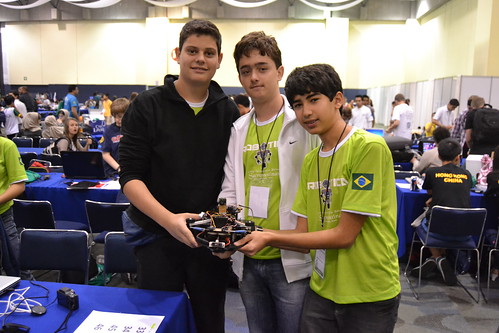
(c) 2012 Complubot, Brazil Rescue A team
And their robots are pretty easy to spot, pitch black with an Arduino Mega in the stomach:
(c) 2012 Complubot, Brazil Rescue A robot
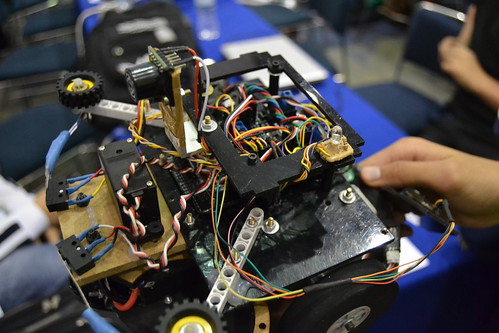
To close the post, I want to show you an image of my favorite robot so far. It is the one made by one of the Mexican teams again in the Soccer B category. It’s platforms are made in wood and it is a masterpiece of a combination of glue-gun and breadboard. Sometimes we think we need so much to build things, and others come to remind us how easy it is to make things happen with whatever you have in hand. If there was a price to the most low-tech solution at this competition, this team would win or be among the finalists.

(c) 2012 Complubot, Mexican Low-Tech team
Oh, yes … and a photo of the team:
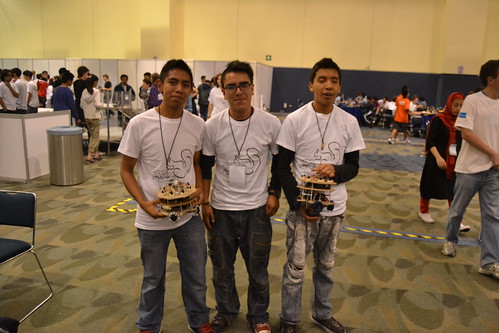
(c) 2012 Complubot, Mexican Low-Tech Champions
Soon: some more images and thoughts about The Arduino Robot, after one week of beta testing in Mexico, stay tuned!
Arduino at RoboCup Mexico 2012
You might have heard the news via other media, but we are building a robot. For almost two years now we have been collaborating with the Complubot Educational Robotics Association from Madrid, Spain. We have gone through several iterations of prototypes, we have been 3D printing wheels, we have looked into color screens, screws, sound speakers …
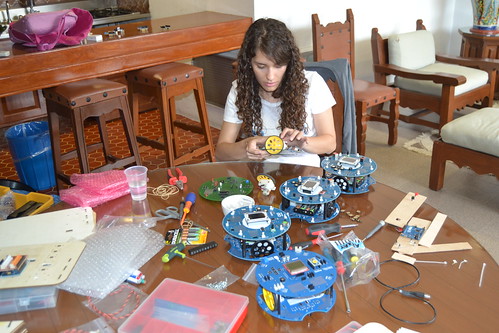
(c) 2012 Complubot, Nerea revising the robots for RC-Mexico 2012
Things are coming along and we are close to the release our first robot. The experience of building this is being amazing and I am sure there will be more bots following this first one.
When we started this process, I knew a lot about digital electronics, but little about robotics. During the last two years I burnt some transistor chips, and made some motors move, I read the books, talked to the people, traveled back and forth to Complubot’s headquarters at a school in Alcala de Henares to check ideas, revise the hardware, and talk about software.
Six months ago, we -Ivan, Nerea, Eduardo and me- passed over the eagle files to Arduino’s hardware guru for him to evaluate the best way to manufacture the robot. We tested battery charging systems, DC-DC converters to improve the response from the motors, tried better display technologies, and now we have our alpha robot running. The project we have been calling “Lottie Lemon” is about to become The Arduino Robot.

(c) 2012 Compubot, Ivan (left) and Nerea talking to some of the RCJ volunteers before opening to the public
We are presenting The Arduino Robot at the RoboCup Mexico 2012 at Complubot’s booth. Nerea, Ivan, and Eduardo are representing Arduino, showing the robots, running a workshop for the attendants to the RCJ event, demoing all the official Arduino boards, and reporting back for the rest of us.
Follow their adventures (in Spanish) at their blog, and come back to ours for more information soon.

Hexy: hands-on with the adorable, affordable hexapod (video)

The Artisan's Asylum has a few guiding principles, one of which is anyone can "make." We assume one of the others is "you can never have too many hexapods." If Stompy, the giant rideable bot, is a bit much for you to handle (or store), then maybe Hexy is more your speed. He's got six legs and 20 servos, but at only $200, he's much cheaper than similar hexapod kits and, most importantly, more adorable. The bot is the brain child of Joseph Schlesinger, a resident at the Somerville hacker space who saw a need for a low-cost but serious robotics kit. Since hitting Kickstarter in May, his creation has raked in roughly $86,000 in pledges, far surpassing his original goal of thirteen grand. We swung by Joe's booth to get a taste of what exactly his hundreds of backers have bought into and to find out what's next for the budding bot entrepreneur.


Continue reading Hexy: hands-on with the adorable, affordable hexapod (video)
Hexy: hands-on with the adorable, affordable hexapod (video) originally appeared on Engadget on Thu, 14 Jun 2012 18:41:00 EST. Please see our terms for use of feeds.
Permalink | Email this | CommentsSome advances in aerial vehicles: bat-inspired smart wings

Researchers from Centro de Automática y Robótica (Universidad Politécnica de Madrid) and from Brown University carried out a very deep research about the specific behavior of bat flight, whose ultimate goal is to replicate the capabilities of bat’s wings by means of an ad-hoc designed micro aerial vehicle (MAV).
From the home page of the project:
[...] this research is oriented towards the development of a biological inspired bat robot platform, that allows to reproduce the amazing maneuverability of these flying mammals. The highly maneuverability is achieved by reproducing the flapping and morphing capabilities of their wing-skeleton structure. This structure is composed by several joints and a membrane that generates the required lift forces to fly.
To mimmic the muscular system that moves the joints of the wing-bones, Shape Memory Alloys (SMA) NiTi wires are used as artificial-muscles. Several challenges in controlling this SMA-based actuation system are regarded in this research.
A lot of research work has already been carried out (see here for a list of publications) and a bat-like MAV prototype has been designed and implemented to both evaluate and validate the research outcomes. Among the other stuff, the core onboard electronic is made up of an arduino-based board, an IMU, a radio transceiver and a rechargeable LiPo battery.

More details on this project can be found here.
[Via: BaTboT project homepage]
Salvius
Primary image

What does it do?
Salvius is my humanoid robotics project that I have been working on over the past year. The robot still requires work before it can move around on its own because I still need to get another motor controller. While I search for another Curtis 12v model: 1204 motor controller I continue to work on many other parts of the robot's design. The robot now has night vision and ultrasonic hearing. You can connect to the robot's computer using any wireless enabled device and control the robots actions.
Cost to build
$650,00
Finished project
Number
Time to build
Type
wheels
URL to more information
Weight
120000 grams
Doodle Bot
Primary image

What does it do?
Draws nonsensical pictures
Having one of those days where your too lazy to do anything? Have a robot doodle for you while you sit back in your favorite chair. This is a very simple drawing robot that was actually started by one of our student engineers. I just made the base plate bigger so I could add a third servo to raise and lower the pen.
My base plate is laser cut acrylic but it could easily have been a small food container, CD or a piece of wood. Just use some double sided tape or hotglue to hold it all together.
Cost to build
Finished project
Complete